DSSERVO DS3235 PRO Servo, 35kg-Class Coreless Digital
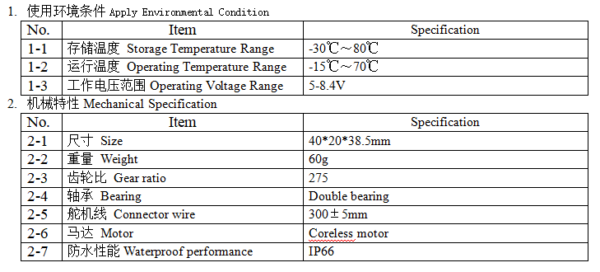
DSSERVO DS3235 PRO is a 35kg-class waterproof coreless digital servo for RC cars and robotics. It provides up to 45 kg·cm stall torque at 8.4 V, with PWM control and IP66-rated protection.
| Model | DS3235 PRO |
|---|---|
| Brand | DSSERVO |
| Motor | Coreless |
| Operating voltage | 5–8.4 V |
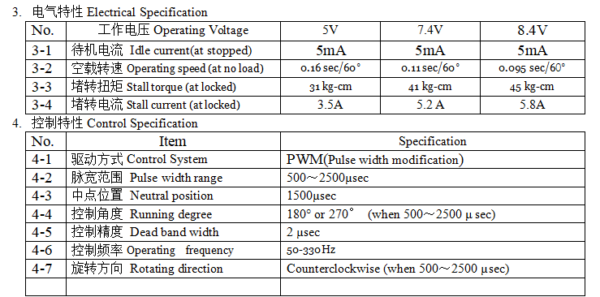
| Stall torque | 31 kg·cm at 5 V; 41 kg·cm at 7.4 V; 45 kg·cm at 8.4 V |
| No-load speed | 0.16 sec/60° at 5 V; 0.11 sec/60° at 7.4 V; 0.095 sec/60° at 8.4 V |
| Stall current | 3.5 A at 5 V; 5.2 A at 7.4 V; 5.8 A at 8.4 V |
| Control | Digital PWM; 500–2500 µs; 50–330 Hz |
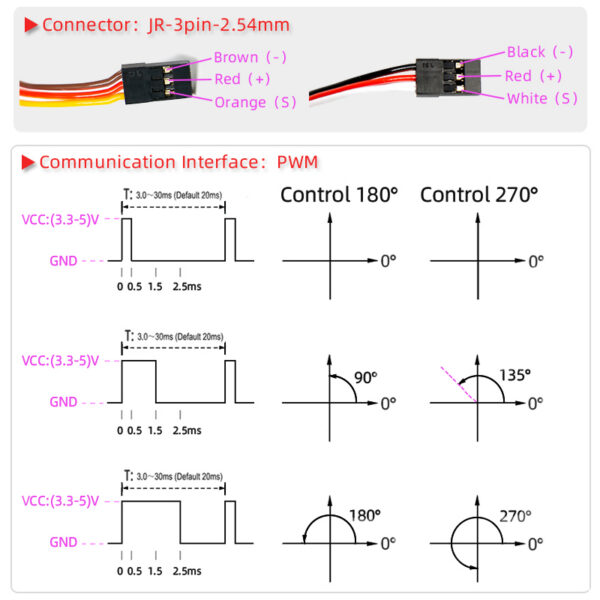
| Control travel | 180° or 270° per supplied diagram; configuration dependent |
| Protection | IP66 |
| Gear ratio | 275:1 |
| Dimensions and weight | 40 × 20 × 38.5 mm; 60 g net weight |
Description
DS3235 PRO servo by DSSERVO is a 35kg-class coreless digital servo for RC vehicle steering and robotics projects. The supplied electrical table lists up to 45 kg·cm stall torque at 8.4 V. The 35kg model class and maximum torque value are specified at different voltage conditions; torque, speed and current vary with the supply voltage.
Coreless digital servo with IP66 protection
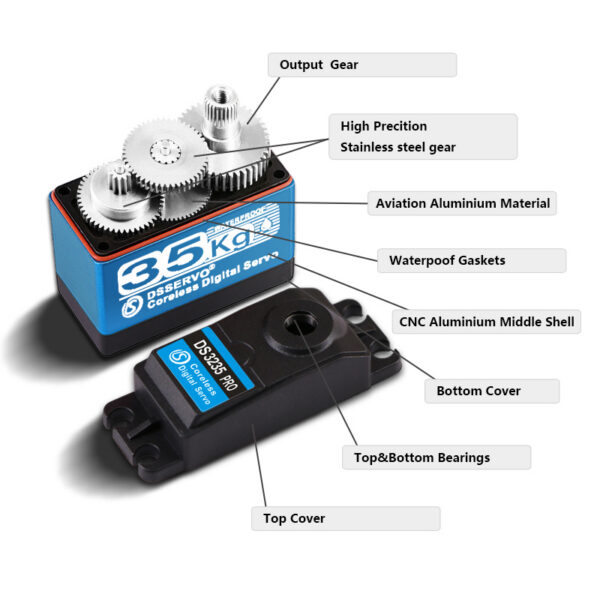
The DS3235 PRO combines a coreless motor with stainless-steel gear components, a CNC aluminum middle case, double bearings and waterproof gaskets. The supplied product specification identifies IP66 protection. Treat this as the servo’s stated protection rating; the documentation does not state an immersion rating. Keep the connector and cable entry appropriately protected in the finished installation, and do not interpret IP66 as a submersion claim.
Torque, speed and current by voltage
| Supply voltage | Stall torque | No-load speed | Stall current |
|---|---|---|---|
| 5 V | 31 kg·cm | 0.16 sec/60° | 3.5 A |
| 7.4 V | 41 kg·cm | 0.11 sec/60° | 5.2 A |
| 8.4 V | 45 kg·cm | 0.095 sec/60° | 5.8 A |
Use a regulated supply within the listed 5–8.4 V operating range. The stall-current values reach 5.8 A at 8.4 V, so size the receiver BEC or servo regulator for the load and expected current peaks. Do not power this high-torque servo from a microcontroller GPIO pin. Stall torque and stall current are locked-shaft ratings, while the speed figures are no-load values; they are not guarantees of continuous loaded performance.
Mechanical fit and construction
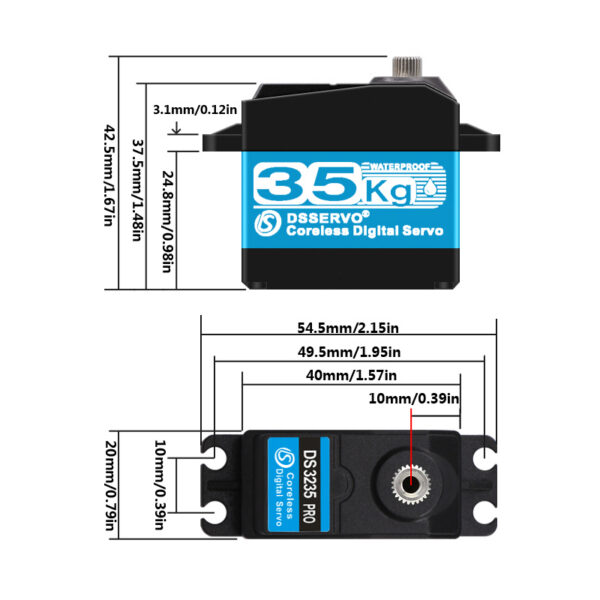
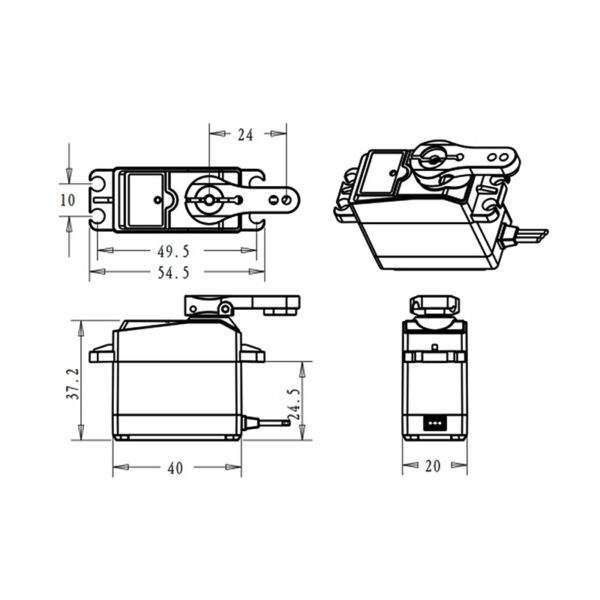
The supplied mechanical table lists a 40 × 20 × 38.5 mm servo body, 60 g net weight, 275:1 gear ratio, double bearings and a 300 ± 5 mm lead. The dimensional graphic shows 54.5 mm overall mounting-tab width and 42.5 mm maximum height including the output spline. Use the drawing to check mounting-hole spacing, shaft clearance and available enclosure space. Confirm the output spline and horn fit with your linkage before assembly.
The illustrated gear assembly labels a stainless-steel output gear, precision stainless-steel gears, an aluminum middle shell, waterproof gaskets, top and bottom bearings, and separate covers. Check mounting, linkage clearance and power capacity before installation.
PWM control and wiring
This digital servo uses PWM control with a 500–2500 µs pulse range, 1500 µs neutral position, 2 µs deadband and a listed operating frequency of 50–330 Hz. The supplied control diagram shows 180° or 270° travel across the pulse range. Actual travel depends on servo configuration and the controller’s pulse endpoints. Verify the required motion before connecting the horn to a constrained steering or robot mechanism.
The product diagram shows a JR-style 3-pin, 2.54 mm connector. It labels brown or black as ground, red as positive supply, and orange or white as signal for the cable versions illustrated. Cable colors may vary by batch, so check the matching product diagram and confirm connector polarity before powering the servo. Incorrect polarity can damage the servo or connected electronics.
Applications and initial setup
The product graphic identifies 1:8, 1:10 and 1:12 RC cars and robots as intended applications. Suitability for a particular steering system or robot joint depends on required force, linkage leverage, mounting geometry, spline fit, controller voltage, signal frequency and travel. Compare those requirements with the table and drawing before ordering. At first power-up, use a supported voltage and check direction and endpoints with the linkage disconnected or mechanism unloaded. Adjust controller endpoints so the mechanism does not bind at either end of travel.
For RC steering, check tire grip, vehicle mass, steering geometry and the load imposed at the servo horn. For a robot joint, consider arm length and the load moment at the output shaft. High stall torque does not mean every application can hold that load continuously without heating or drawing high current. Leave a suitable margin in the power system and avoid prolonged locked-shaft operation.
Package contents
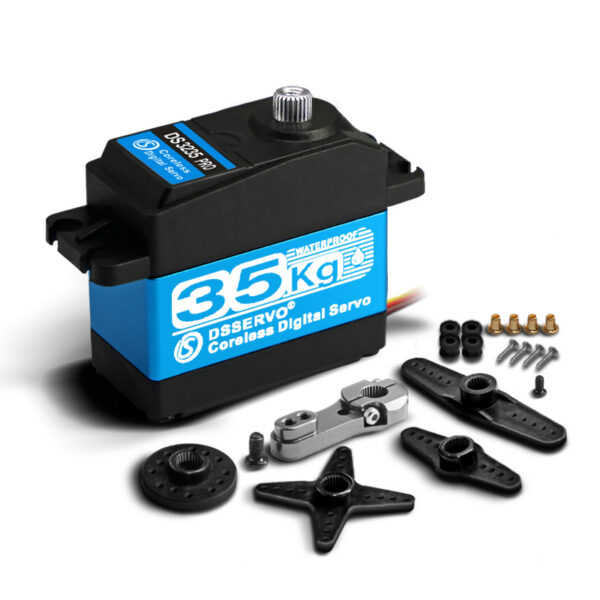
The matching Coreless DS3235 PRO supplier quotation lists one DS3235 digital metal servo, one 25T adjustable metal servo arm and one accessory set as pictured. The quotation does not enumerate every accessory or its quantity. The product images show several horns and small mounting parts; confirm any critical screw, horn shape or quantity before purchase.
Frequently asked questions
Is the DS3235 PRO a 35kg-cm servo? It is marketed as a 35kg-class model. The supplied table lists 31 kg·cm at 5 V, 41 kg·cm at 7.4 V and 45 kg·cm at 8.4 V under stall conditions.
Can it run at 8.4 V? The supplied operating range is 5–8.4 V. Keep the supply within this range and ensure the regulator can provide the current required by your load.
Does the diagram guarantee 270° travel? No. It shows 180° or 270° control options, but actual travel depends on servo configuration and controller endpoints. Test travel before attaching a constrained linkage.
Can it be submerged? The product specification lists IP66 but does not provide an immersion rating. Do not treat the stated rating as approval for underwater operation.
Additional information
| Model | DS3235 PRO |
|---|---|
| Brand | DSSERVO |
| Motor | Coreless |
| Operating voltage | 5–8.4 V |
| Stall torque | 31 kg·cm at 5 V; 41 kg·cm at 7.4 V; 45 kg·cm at 8.4 V |
| No-load speed | 0.16 sec/60° at 5 V; 0.11 sec/60° at 7.4 V; 0.095 sec/60° at 8.4 V |
| Stall current | 3.5 A at 5 V; 5.2 A at 7.4 V; 5.8 A at 8.4 V |
| Control | Digital PWM; 500–2500 µs; 50–330 Hz |
| Control travel | 180° or 270° per supplied diagram; configuration dependent |
| Protection | IP66 |
| Gear ratio | 275:1 |
| Dimensions and weight | 40 × 20 × 38.5 mm; 60 g net weight |
Custom Parts for Your Project
Ask about CNC machining or 3D printing for your part.
Custom CNC Parts
Send a drawing or CAD file, material, quantity, finish requirements, and application.
Request a Quote3D Printed Parts
Send a drawing or 3D file, quantity, intended use, and material or finish requirements.
Request a Quote