Microduck Robot Duck Replica with P0090FH Servo
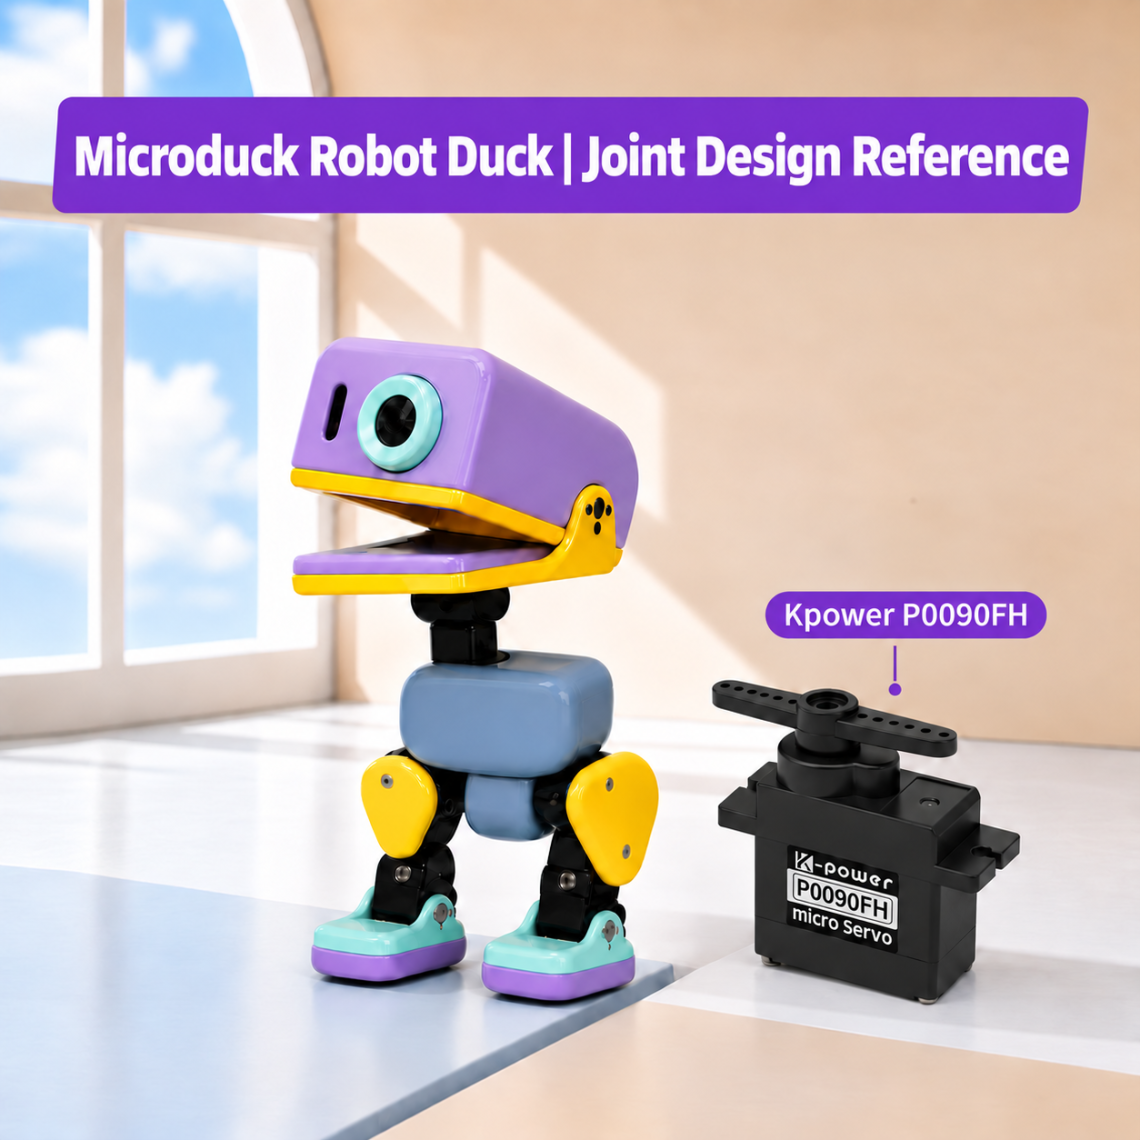
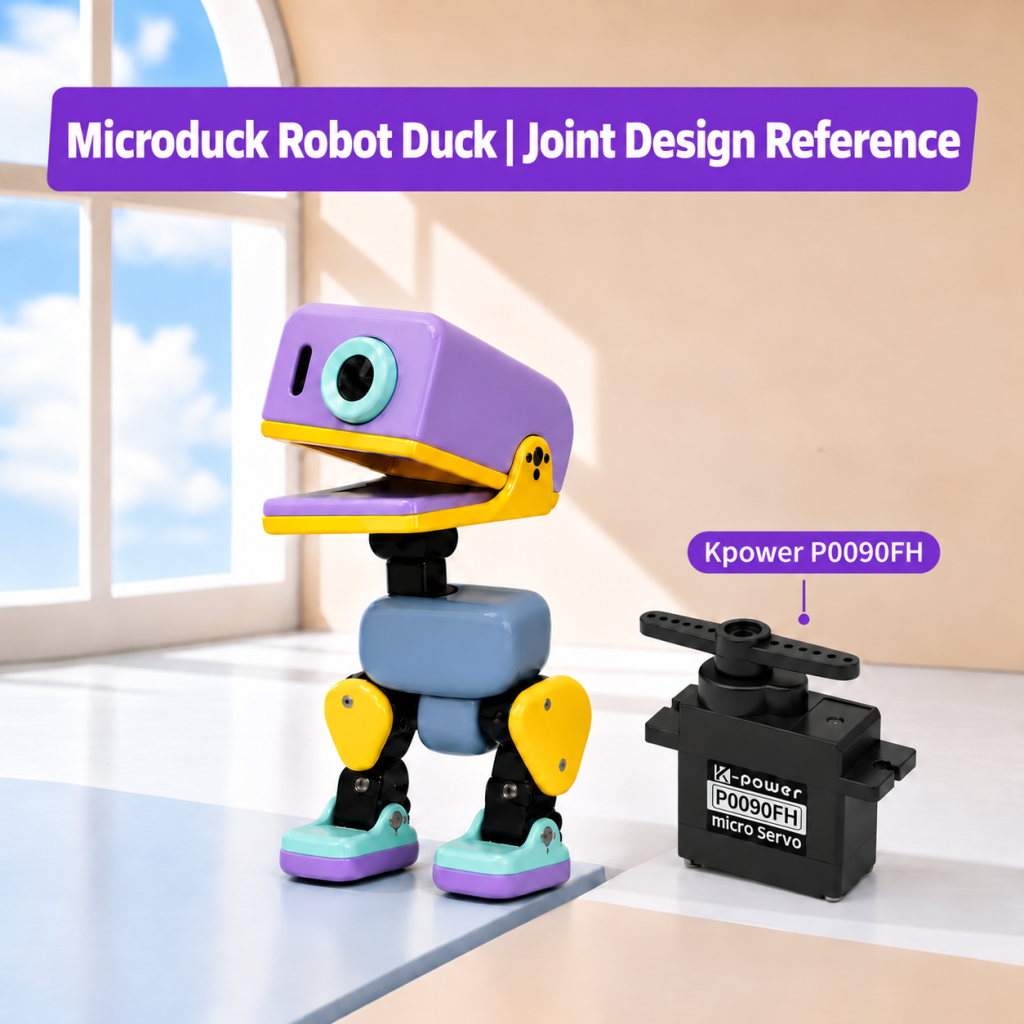
Our team built this Microduck-inspired replica with the Kpower P0090FH servo, 3D-printed parts and CNC-machined components. The lead image is a design reference, not a photo of the assembled replica.
1. How Microduck Began
Microduck grew from a question at Pollen Robotics. While building Reachy Mini, the team asked what a small robot could do if it moved through the world instead of staying on a desk. The answer was a 25 cm open-source biped with 15 motors, a camera, a depth sensor, two IMUs and an articulated beak. It can walk, sit, crouch and recover from many common falls.
Read more: Pollen Robotics’ official introduction · Microduck source code.
2. How We Built Our Replica
For this independent replica, we designed and assembled 3D-printed and CNC-machined parts around the Kpower P0090FH servo. This is an independent replica. It is not affiliated with or endorsed by Pollen Robotics. The adjacent R&D graphic is a supplier illustration. Its figures do not describe City of Machinery or this project.
3. P0090FH: The Servo Used in Our Replica
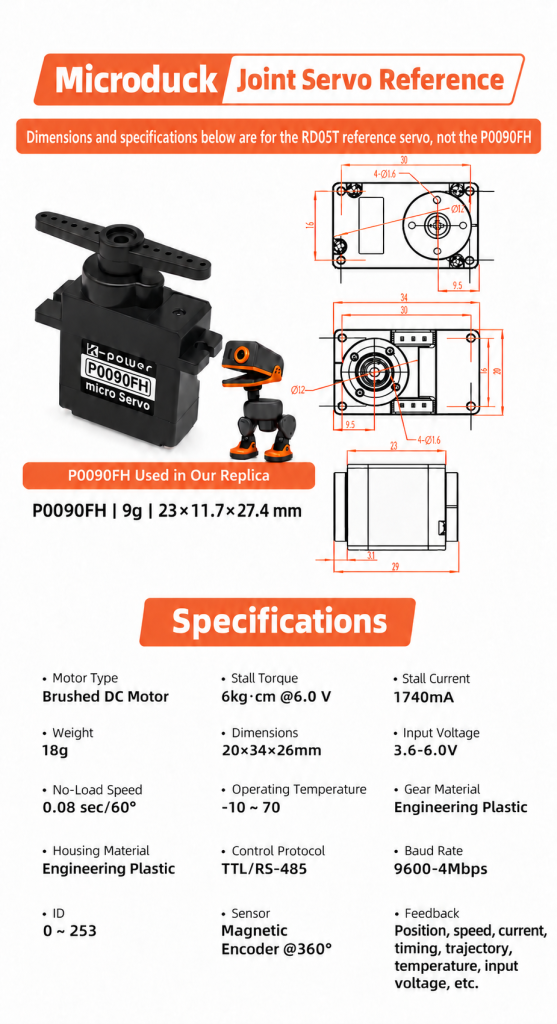
The replica uses the Kpower P0090FH 9 g clutch micro servo as a joint actuator. The product listing specifies 4.8–6.0 V operating voltage, PWM control, 2.0 kg·cm stall torque, 0.5 kg·cm rated torque, and a body size of 23 × 11.7 × 27.4 mm. Listed weight is 9 g.
The graphic lists RD05T dimensions and specifications. They are reference data, not P0090FH specifications. The P0090FH values above come from our product listing. Stall torque and rated torque describe different operating conditions. Check each joint’s load, travel and supply voltage. The listed values do not prove direct interchangeability with Microduck’s original actuators.
4. Custom CNC Parts for Your Project
City of Machinery supports CNC machining for custom robotics parts. Send us a drawing, sample or design requirement. Our team will review it and discuss machining options for your part. The adjacent factory graphic is a supplier illustration. It does not show City of Machinery’s facility or a part from this replica.